Ruoqu Chen

Tsinghua University. Ph.D. Student

crq_2.jpg

Feel free to reach out!

I am a first-year Ph.D. student at the Institute for Interdisciplinary Information Sciences (IIIS), Tsinghua University, advised by Prof. Mengdi Xu. My research interests lie in dexterous manipulation and robot interaction. I received my bachelor’s degree from the Department of Automation at Tsinghua University, where I was fortunate to be advised by Prof. Xiang Li and Prof. Mingguo Zhao, and I joined the Stanford Vision and Learning Lab (SVL) as a summer research intern in 2025.

Open to Collaboration

I particularly enjoy hands-on work with robotic systems, from building experimental setups to deploying and evaluating new policies on real hardware.

My past research experience has helped me build a comprehensive, hands-on foundation in robotics, spanning motion control, planning, perception, and robot learning. I have extensive experience working with diverse robotic platforms, particularly dexterous hands and robotic manipulators, from low-level control and teleoperation to policy training and real-world deployment.

news

Nov 2026 WEAVE, Uni-VLaT, ToolDex, and EgoHSI3R are accepted to CoRL 2026 workshops! See you at the poster session!
Sep 2026 Dex-X is accepted to CoRL 2026! Check out the paper and the project page. CATok is accepted to NeurIPS 2026 as a Poster! Check out the project page.
Sep 2026 Started my Ph.D. at the Institute for Interdisciplinary Information Sciences (IIIS), Tsinghua University. :tada:

selected publications

All publications →

Dexterous Manipulation & Contact-Rich Robot Learning
  1. dexx.jpg
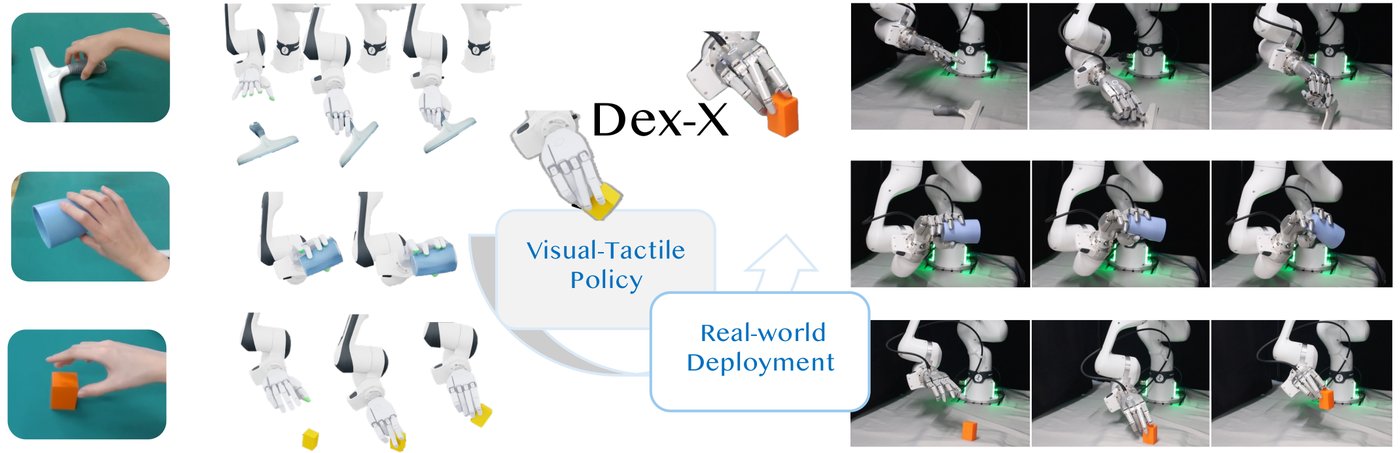
    Dex-X: Learning Visual-Tactile Dexterous Manipulation From Human Videos with Simulated Interaction

    Learning visual-tactile dexterous manipulation from human videos through simulated interaction.

    Ruoqu Chen, Feixiang Ruan, Liu Cao, Zihao Wang, Botian Xu, Shiqin Tong, Jiajun Liu, Mingzhi Pei, Chenyu Zhang, Wanli Xing, Kaifeng Zhang, and Mengdi Xu†
    CoRL 2026
    RSS 2026 Workshop on Dexterous Manipulation (Spotlight)
  1. univlat.webp
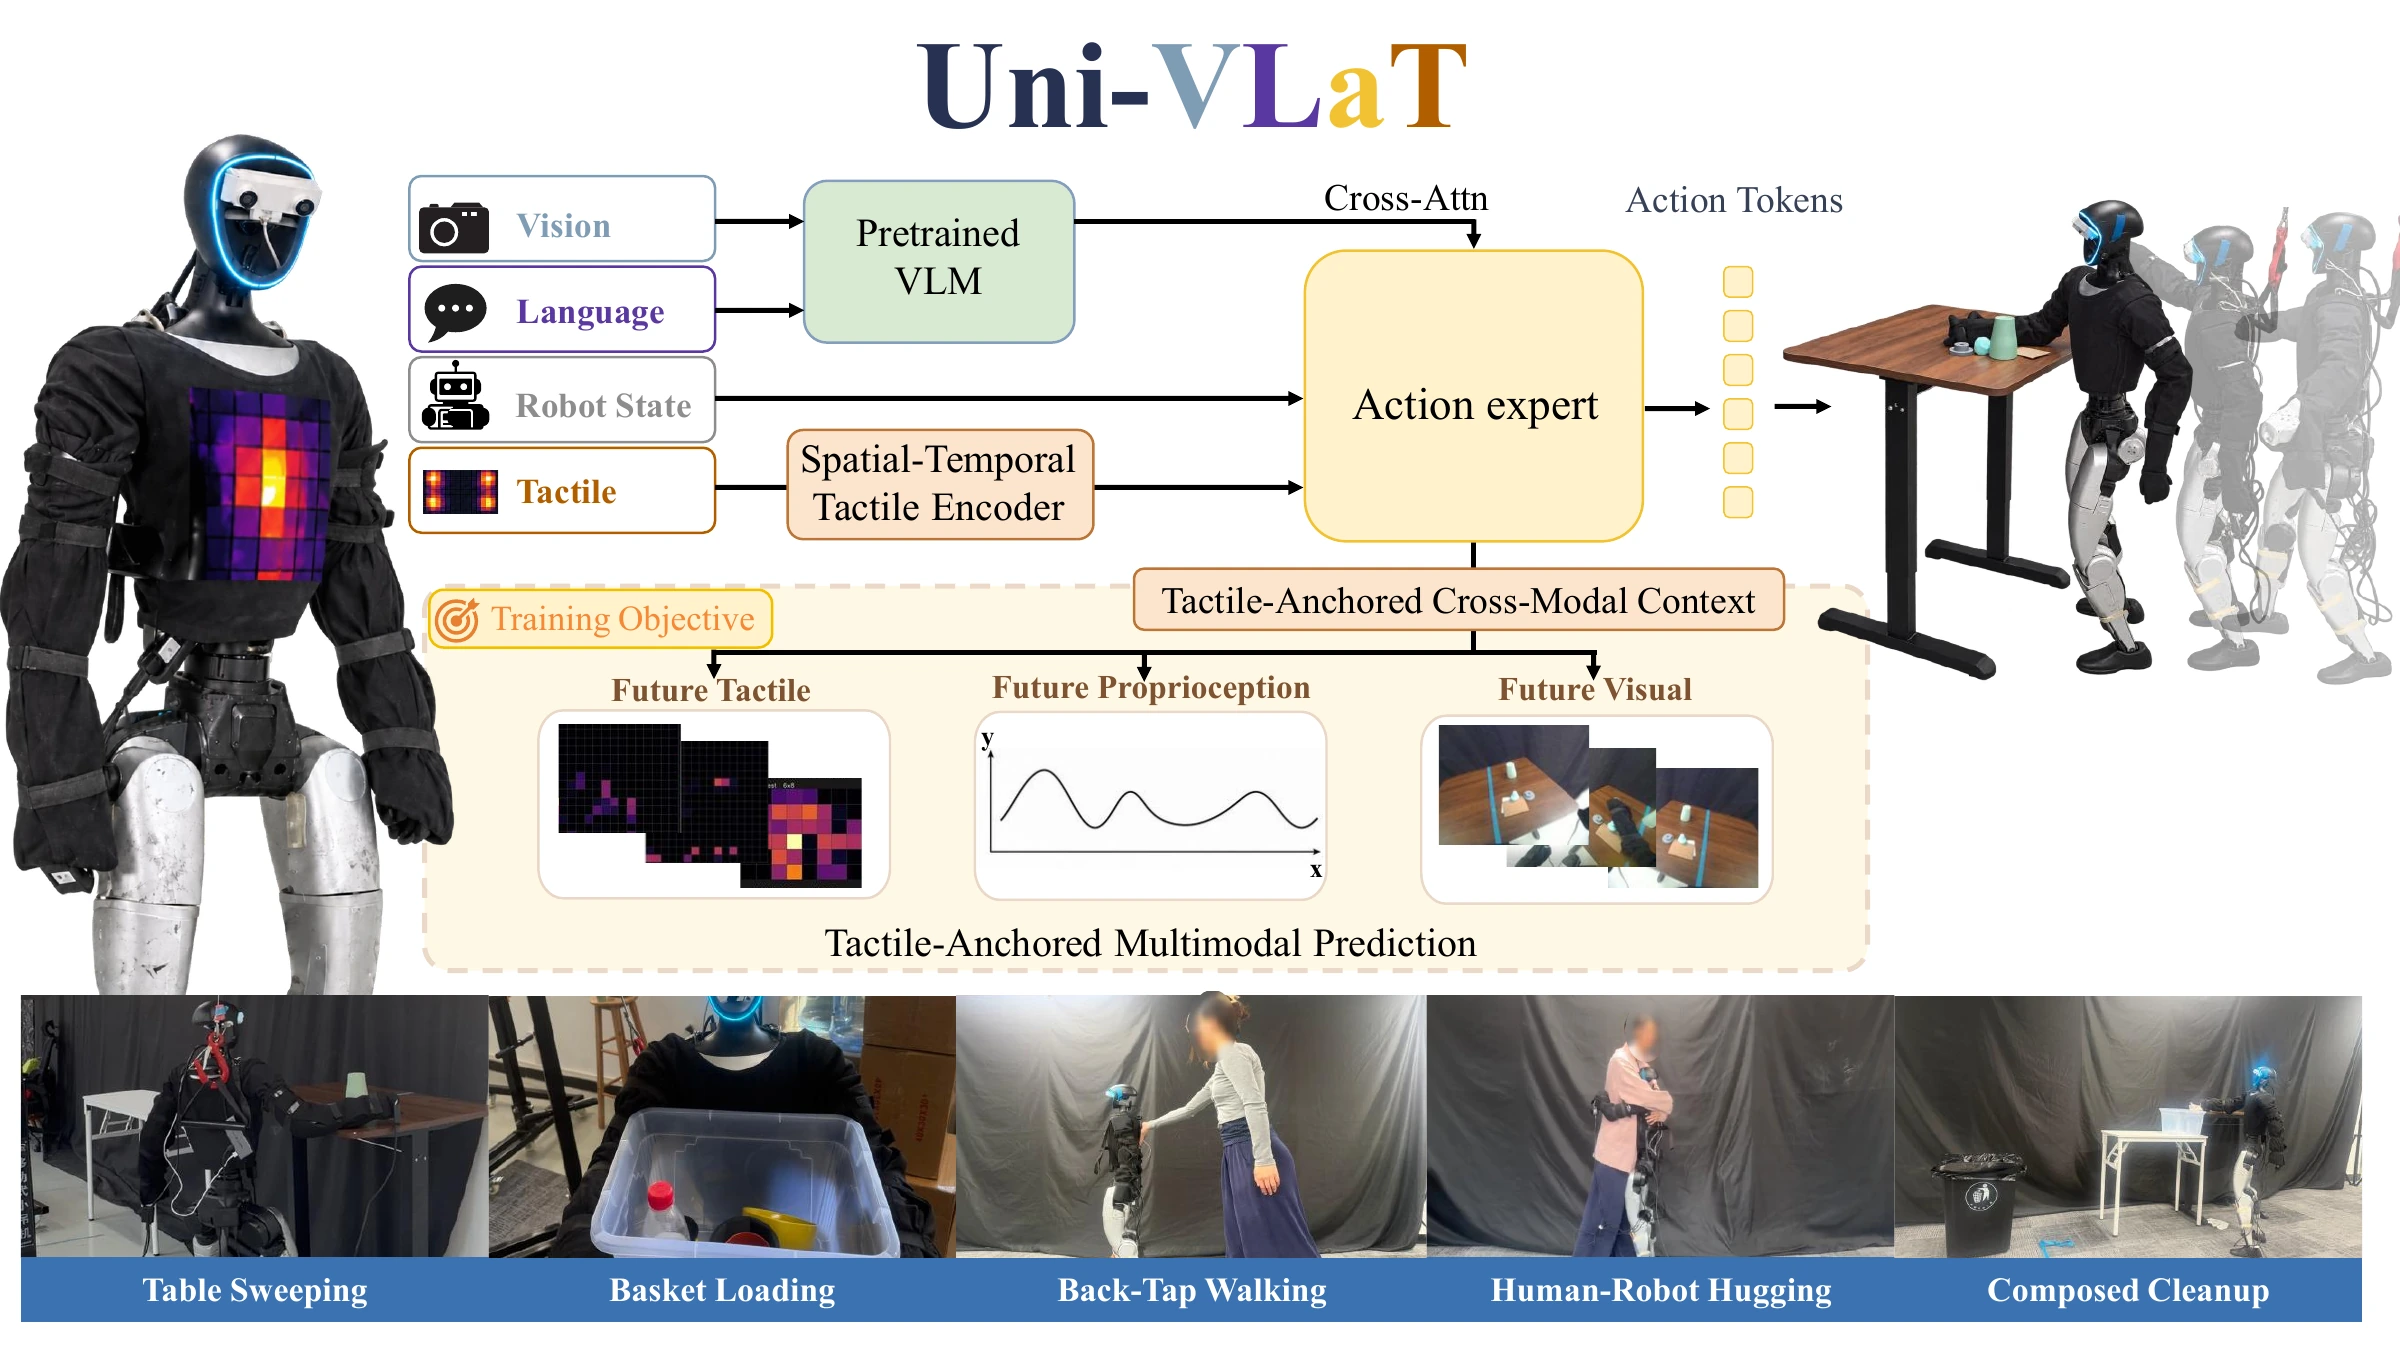
    Uni-VLaT: Whole-Body Tactile Adaptation of VLA Policies for Humanoid Loco-Manipulation

    Adapting pretrained VLA policies with whole-body touch for contact-rich humanoid tasks.

    Zihao Wang*, Shutong Liu*, Siqi Zheng, Liu Cao, Ruoqu Chen, Rundong Liu, Yanchao Yang, and Mengdi Xu†
    arXiv preprint, 2026
  1. dp_out.jpg
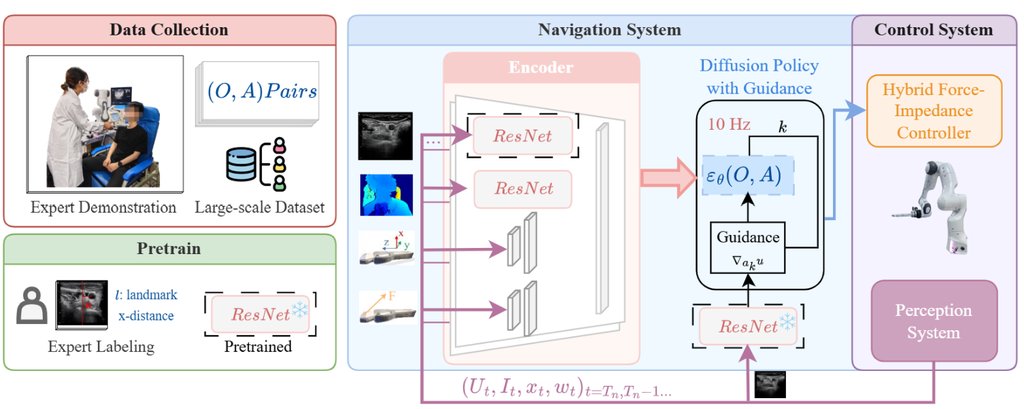
    UltraDP: Generalizable Carotid Ultrasound Scanning with Force-Aware Diffusion Policy

    Generalizing autonomous ultrasound scanning with a force-aware diffusion policy.

    Ruoqu Chen, Xiangjie Yan, Kangchen Lv, Gao Huang, Zheng Li, and Xiang Li†
    IROS 2025
  1. egohsi3r.png
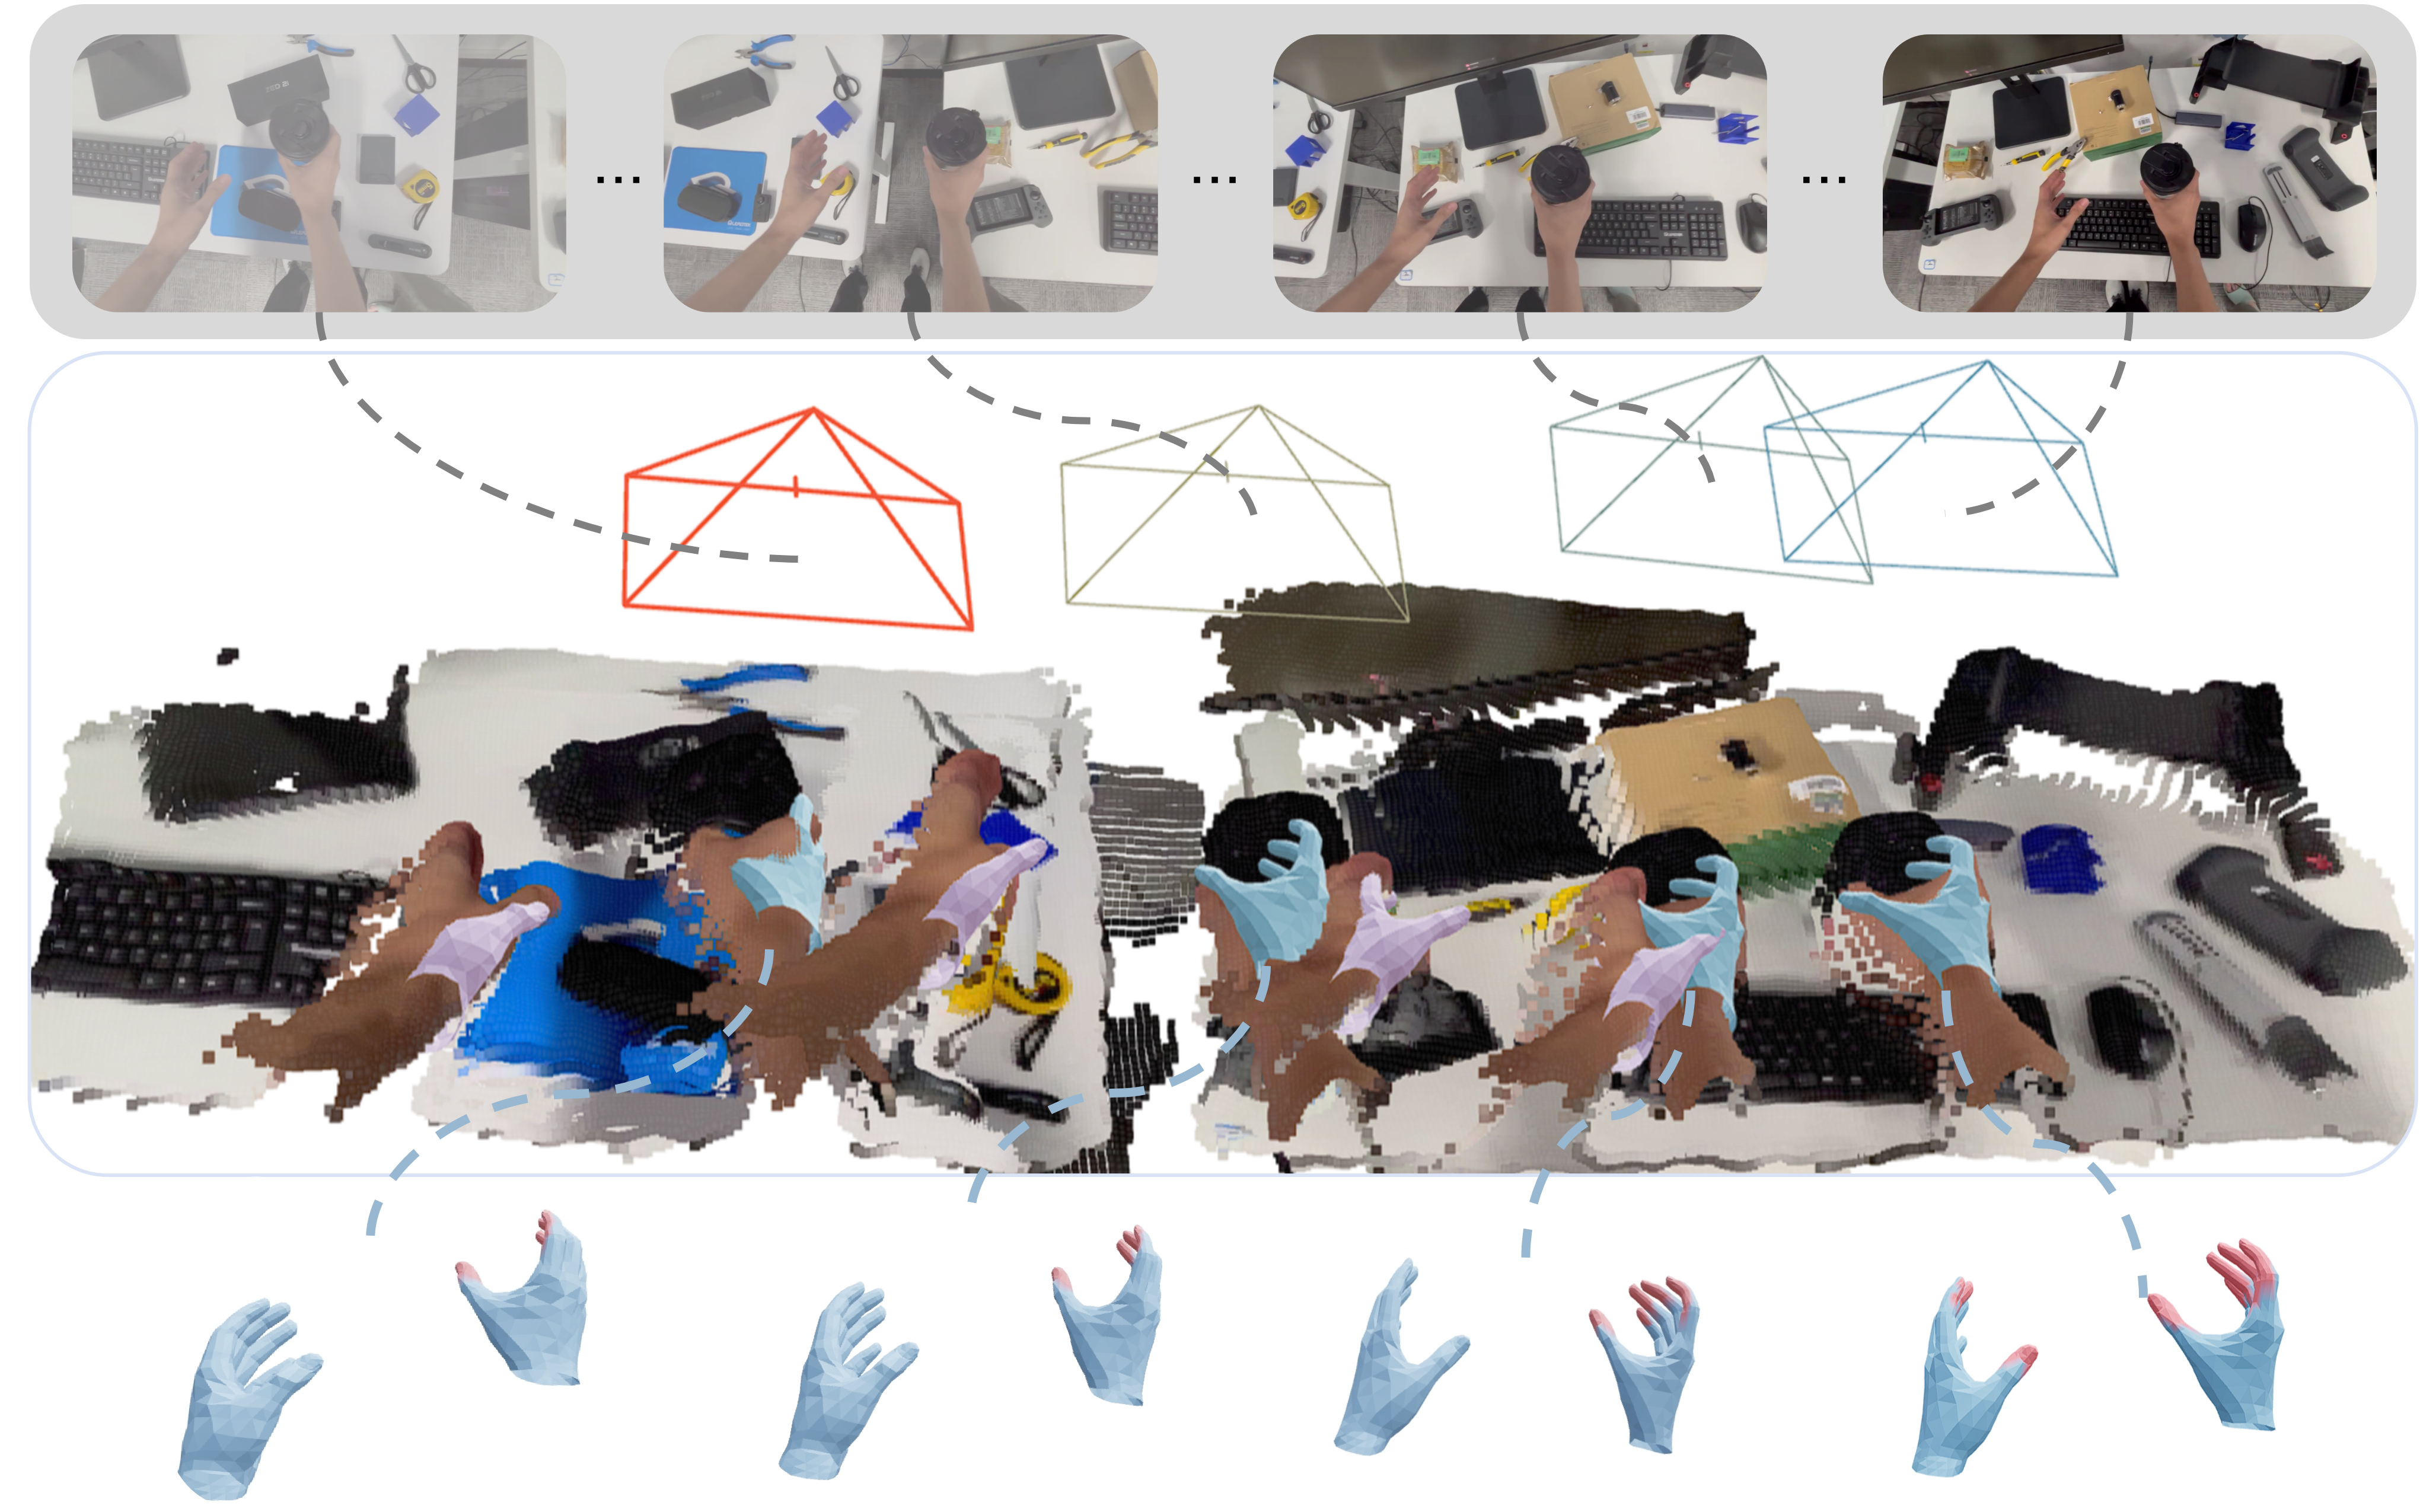
    EgoHSI3R: Online 4D Hand-Scene Interaction Reconstruction from Egocentric Video

    Reconstructing camera motion, dense scenes, world-space hands, and hand contact from egocentric video in a streaming manner.

    CoRL 2026 Workshop Scaling H2R, Oct 2026
    Accepted
  1. tooldex.png
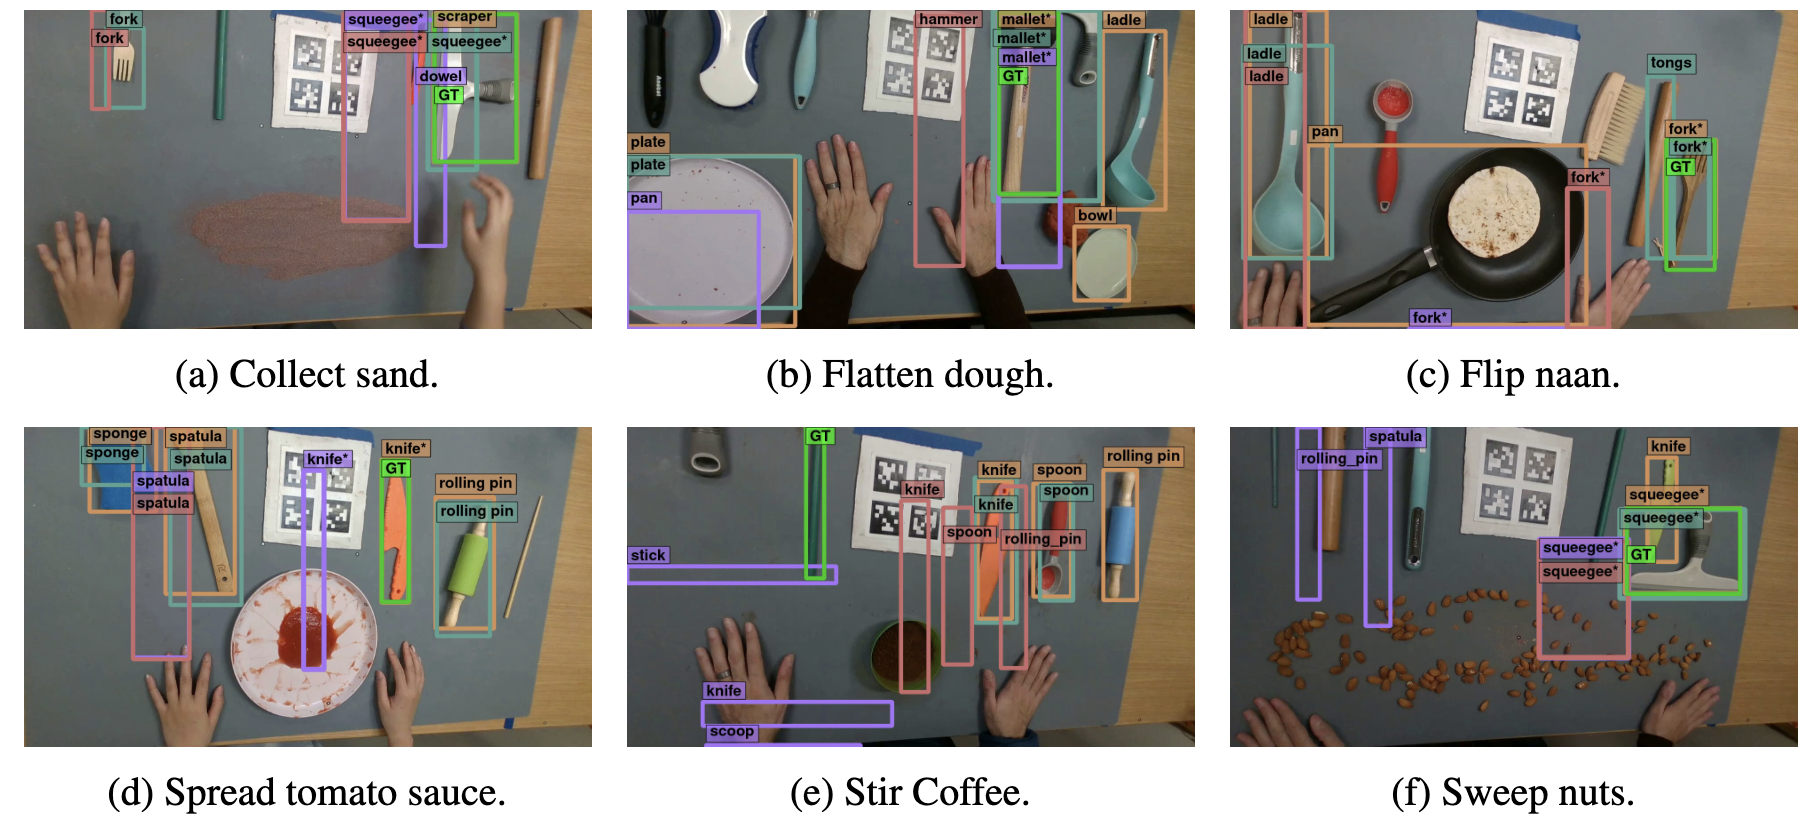
    TOOLDEX: An Ego-Exo Human Demonstration Dataset for Creative Physical Tool Use

    Learning creative physical tool use from multi-view human demonstrations with hand and object annotations.

    Anonymous Authors
    CoRL 2026 Workshop, Oct 2026
    Accepted

Robot Interface

  1. uni-robot-agent.png
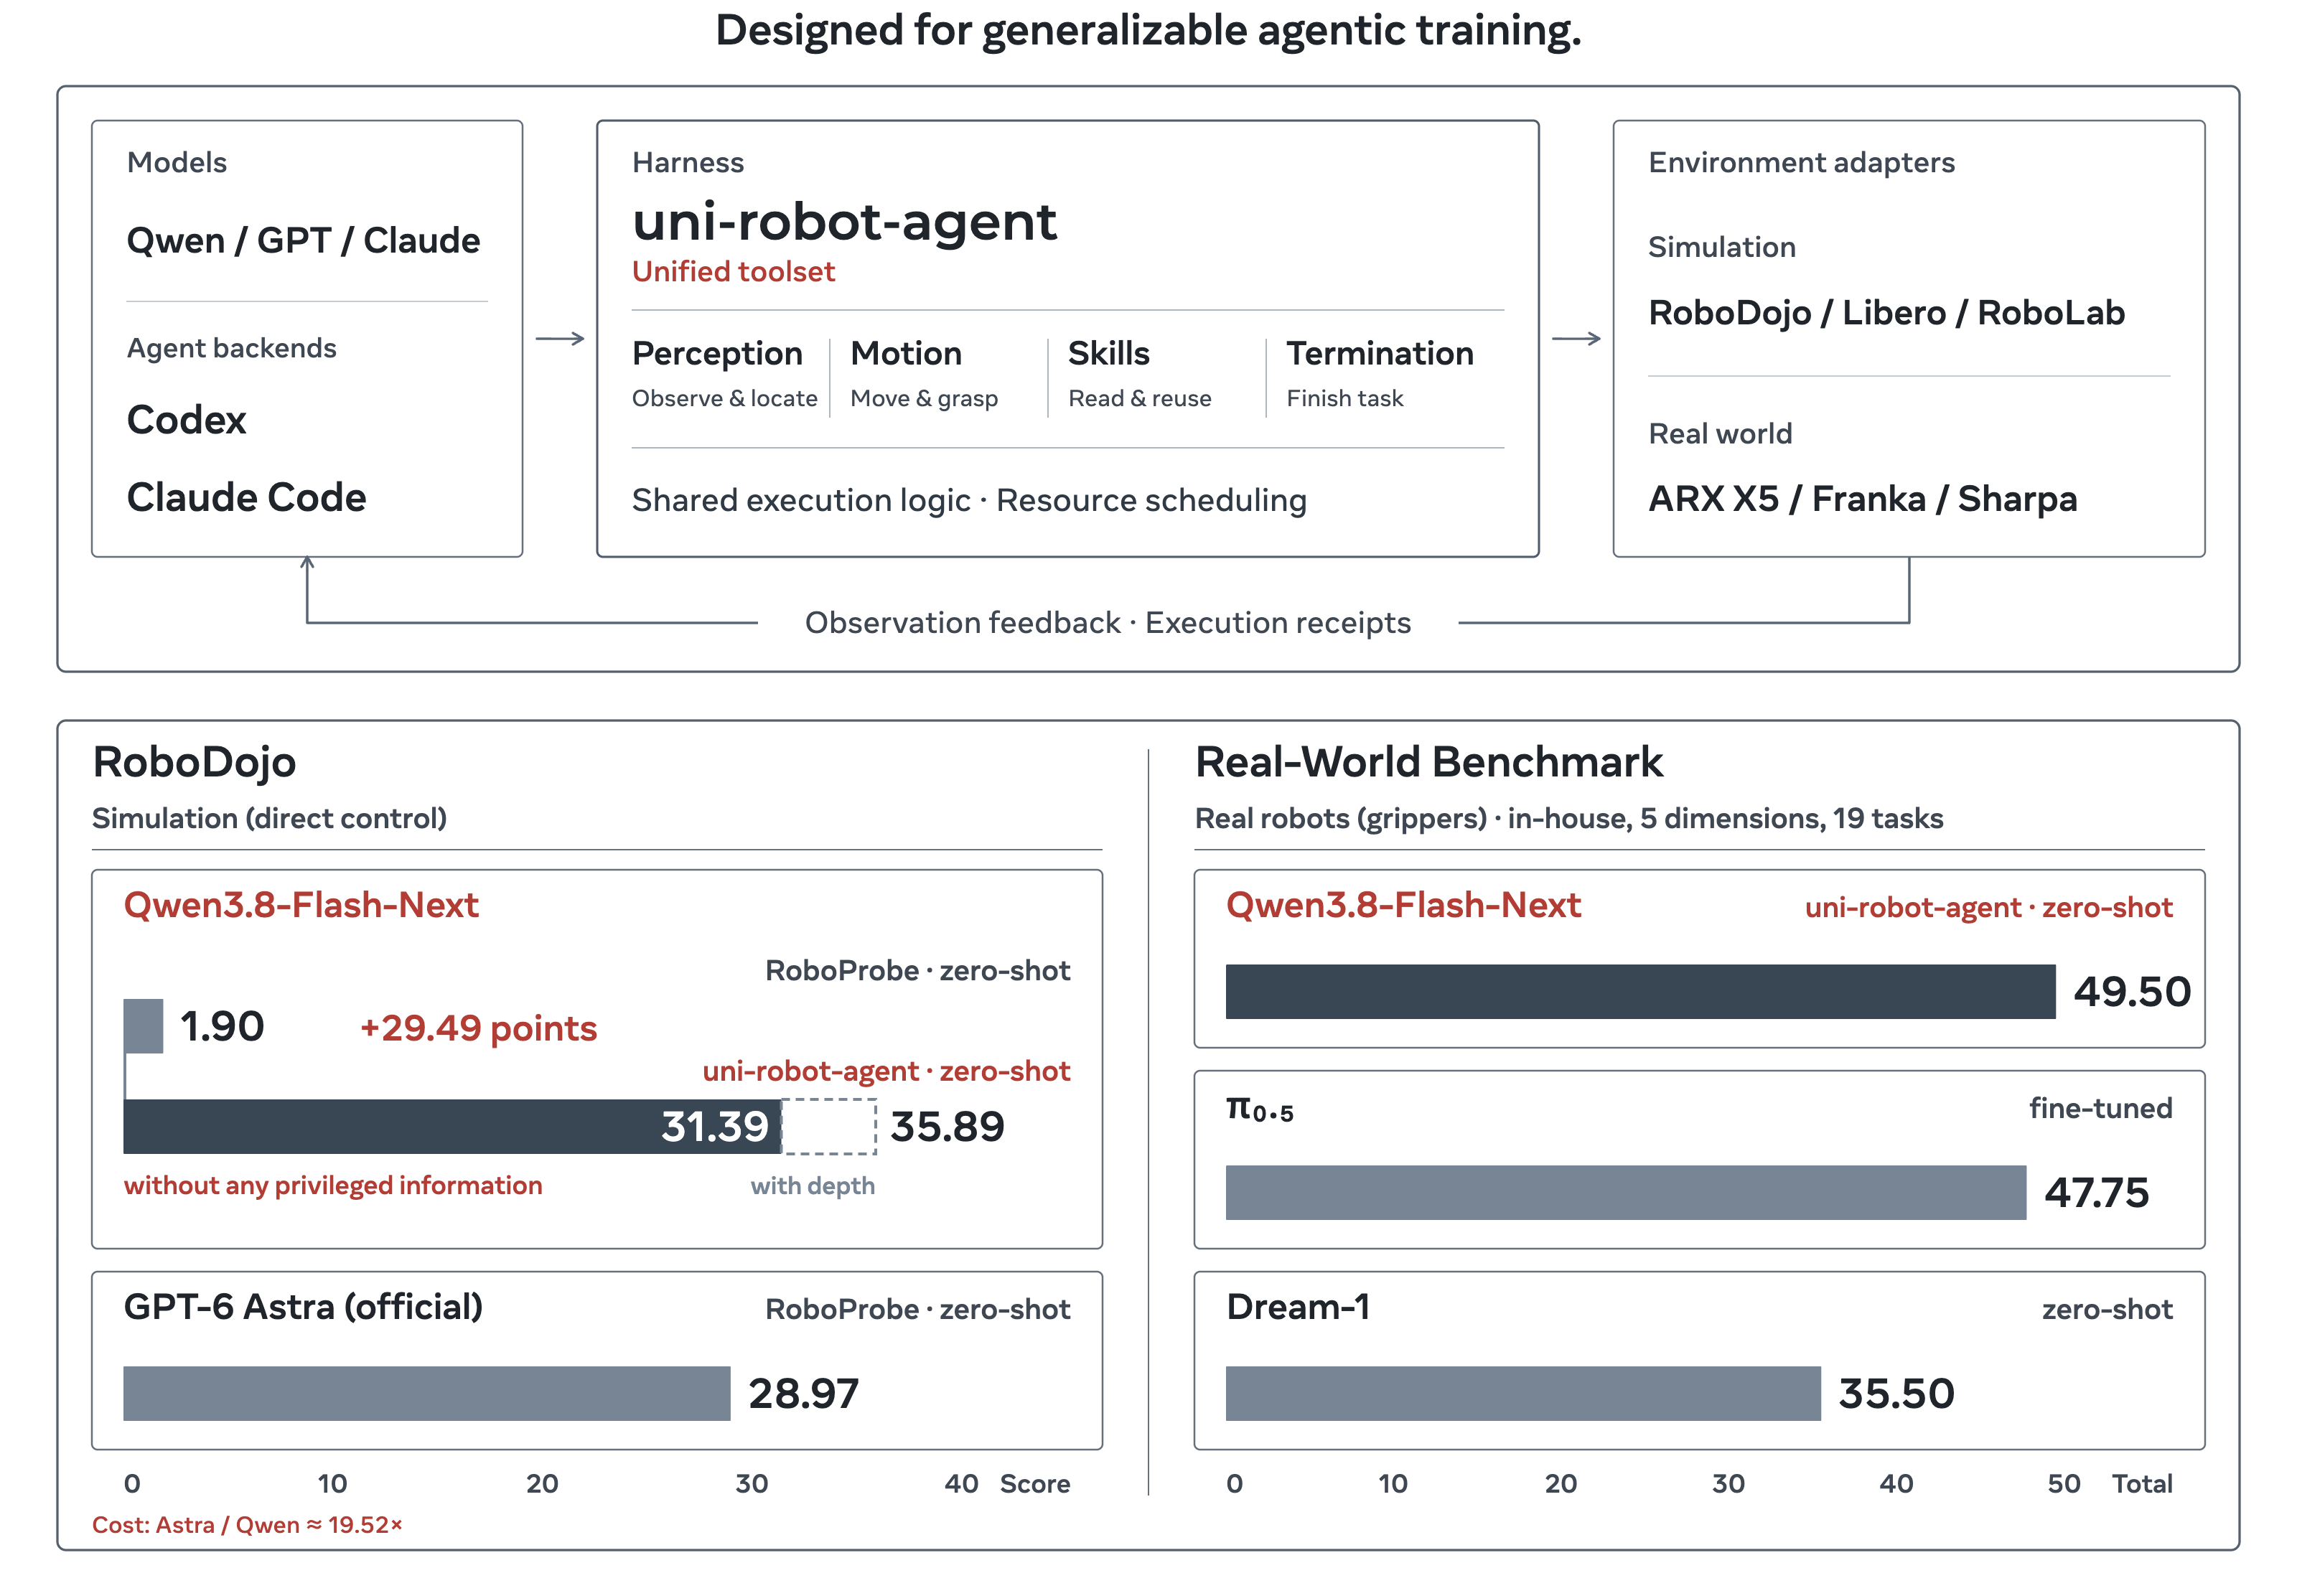
    Democratizing Robot-Use Agents: A Unified Harness with Open Models
    Jiarui Yuan, Yuxin Zuo, Xiaoyu Huang, Wenbo Zhang, Kwanyoung Park, Junlin Yang, Tianxiang Zhang, Ruoqu Chen, Yutao Ouyang, Bingxiang He, Xingtai Lv, Hongjin Wu, Jiajun Liu, Jiahao Zhao, Tianwei Luo, Haozhan Li, Cheng Qian, Jiaxin Ge, Huan-ang Gao, Kaisen Yang, Jiaqi Deng, Qixin Xu, Siqiao Huang, Bowen Zhou, Mengdi Xu, Zhiyuan Liu, Pieter Abbeel, and Ning Ding
    arXiv preprint, Nov 2026
  1. rldexagents.svg
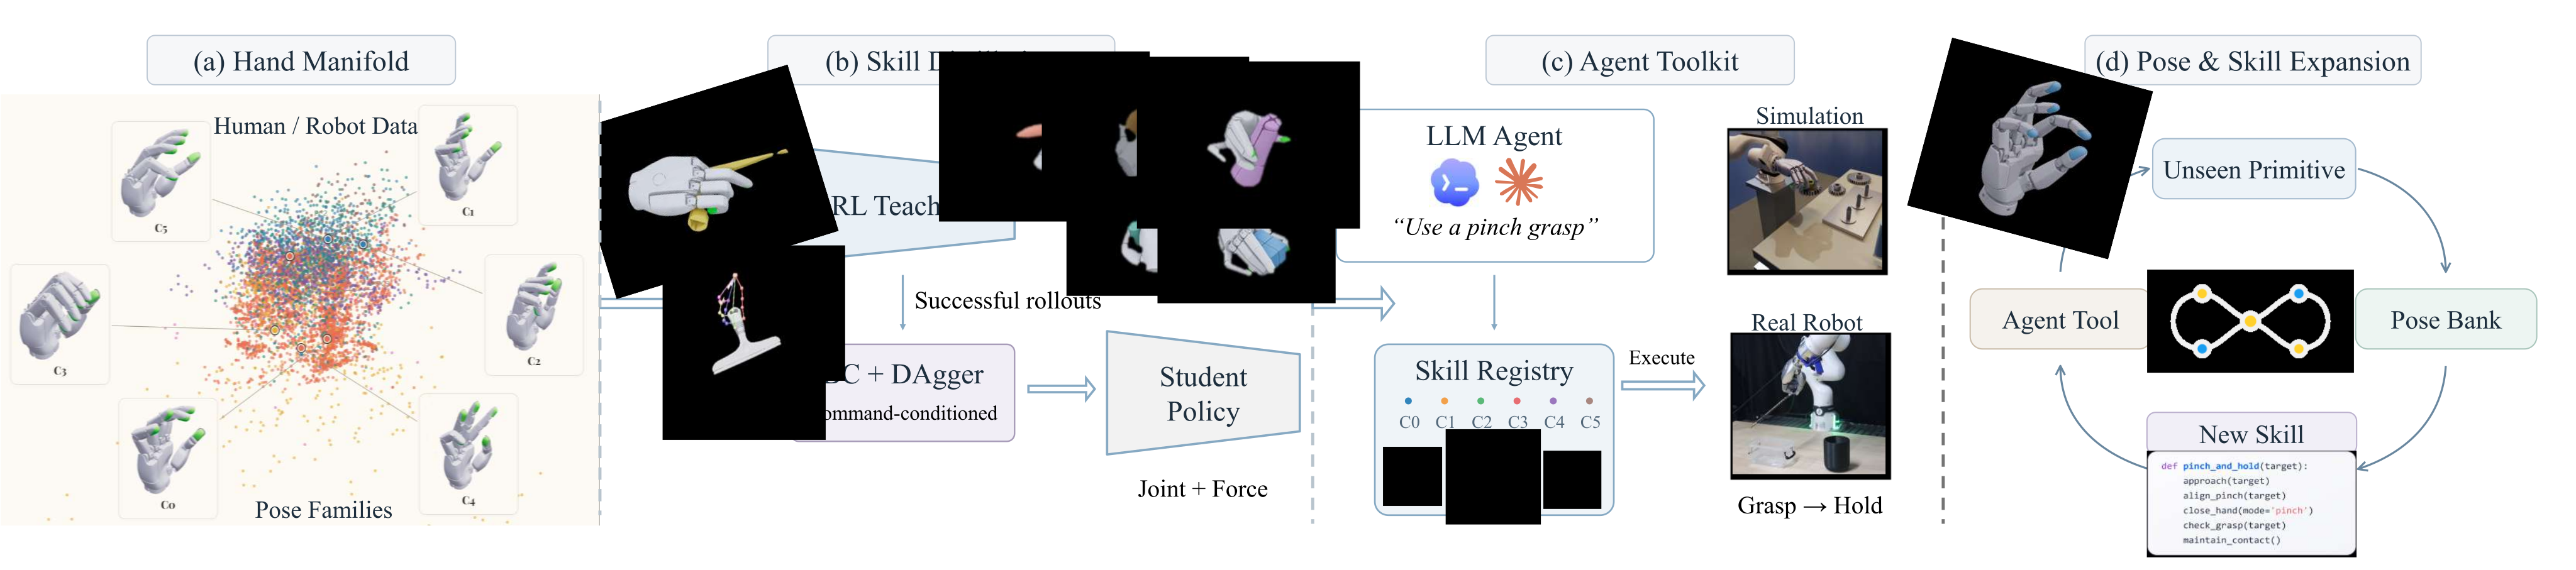
    DexSkill: Learning and Refining Dexterous Manipulation Skills through Interaction

    Grounding hand motion data into reusable dexterous skill banks that LLM agents can retrieve, compose, and extend.

    Ruoqu Chen, Shutong Liu, Feixiang Ruan, Weili Fu, Zihao Wang, and Mengdi Xu†
    Technical Report, Oct 2026
  1. rose.png
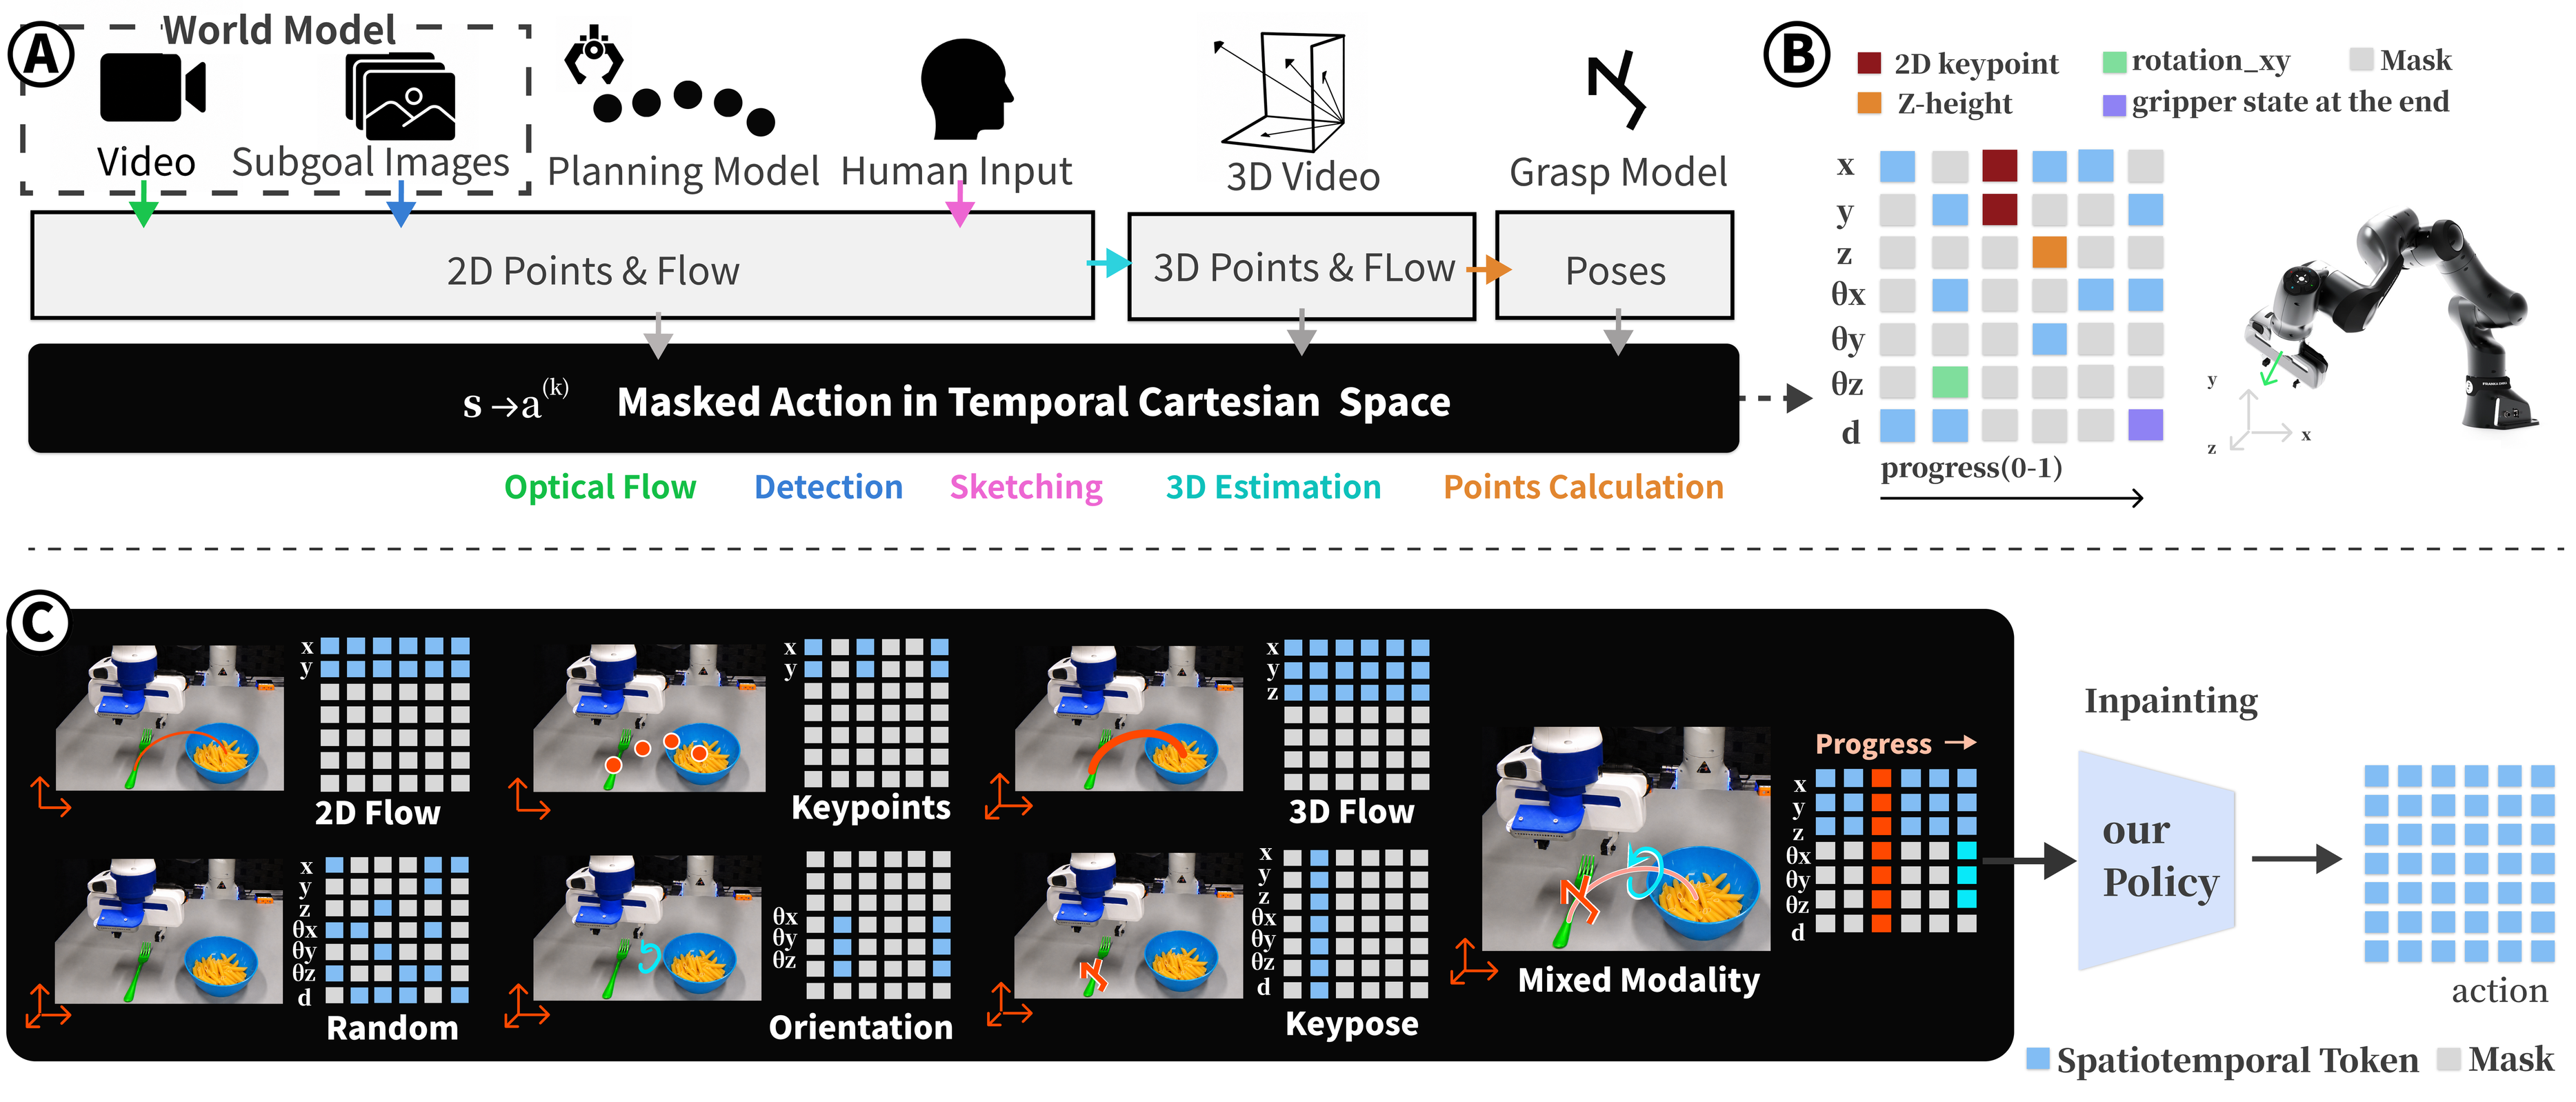
    Robotic Spatiotemporal Editing: A Unified Interface for Controllable Action Generation via Masked Action Reconstruction
    Yanbang Li, Bu He, Yi Tian, Yu-Chiao Huang, Chenyu Zhang, Ruoqu Chen, Yuanzhe Liu, Yuxiang Gao, and Mengdi Xu
    arXiv preprint, Oct 2026

Whole-Body Control & Loco-Manipulation
  1. weave.jpg
    WEAVE: Learning Whole-Body Dexterous Loco-Manipulation from Human–Object Interactions

    Learning coordinated whole-body and dexterous hand control from human-object interactions.

    Liu Cao, Xingze Wu, Jingzhi Cui, Botian Xu, Mingzhi Pei, Ruoqu Chen, and Mengdi Xu
    arXiv preprint, Oct 2026
  1. humit.jpg
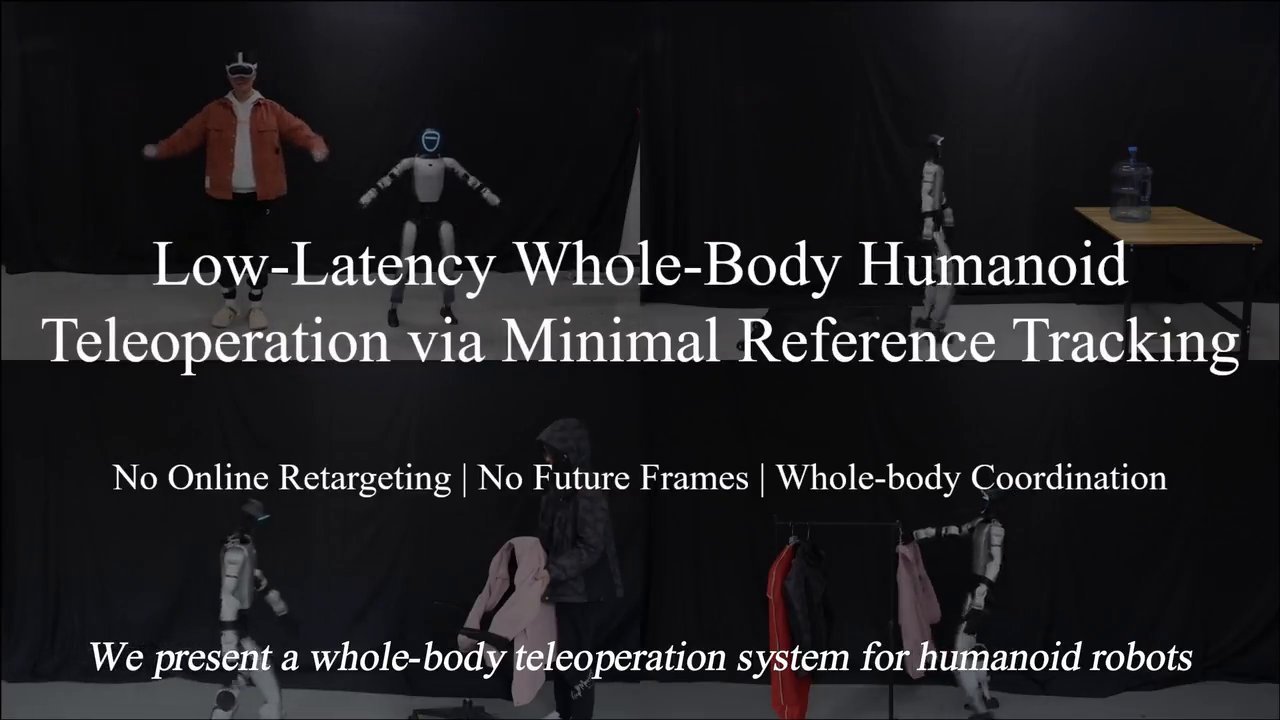
    HuMiT: Low-Latency Whole-Body Humanoid Teleoperation via Minimal Reference Tracking

    Enabling responsive whole-body humanoid teleoperation from sparse human keypoints.

    Liu Cao, Botian Xu, Ruoqu Chen, Jiajun Liu, Mingzhi Pei, Zihao Wang, Zhongyu Li, and Mengdi Xu†
    Preprint (Under Review), Oct 2026
  1. wbmpc.jpg
    Whole-Body Model Predictive Control for Mobile Manipulation with Task Priority Transition

    Coordinating mobile manipulation tasks through smooth priority transitions in whole-body control.

    Yushi Wang, Ruoqu Chen, and Mingguo Zhao†
    ICRA 2025

research experience

  • Sharpa Robotics Oct 2025–May 2026
    Research Collaborator

    Developed learning-based dexterous manipulation algorithms and deployed visual-tactile policies on real robotic systems.

  • Stanford University Summer 2025
    Summer Research Intern · Stanford Vision and Learning Lab (SVL)