RLDexAgents / Research Supplement / 27 October 2026
Hand Pose & HOI Manifolds
Explore hand configurations, inspect representative poses and recorded interactions, and compare geometric coverage with PCA reconstruction and compact pose banks.
6,241HOI reference samples
6Link-near + distance clusters
6Isaac Sim teacher demonstrations
13DComponents for 95% Sharpa variance
01
Explore the hand-object manifold
The default representation is link_near_and_distance_joint. It combines joints, palm-object relations, object shape, 5 mm proximity indicators for 26 hand links, and size-normalized distances. Drag to rotate, scroll to zoom, and color points by source, cluster or object. Select a point or star to inspect its representative and available videos. Cluster numbers are specific to each representation.
Each point describes one interaction configuration from 6,241 HOI references. PCA axes are scaled separately by their standard deviations for visualization; raw coordinates remain available in the point details. Proximity in this 3D view does not establish proximity in the full feature space. The E1 pose analysis below uses a separate population.
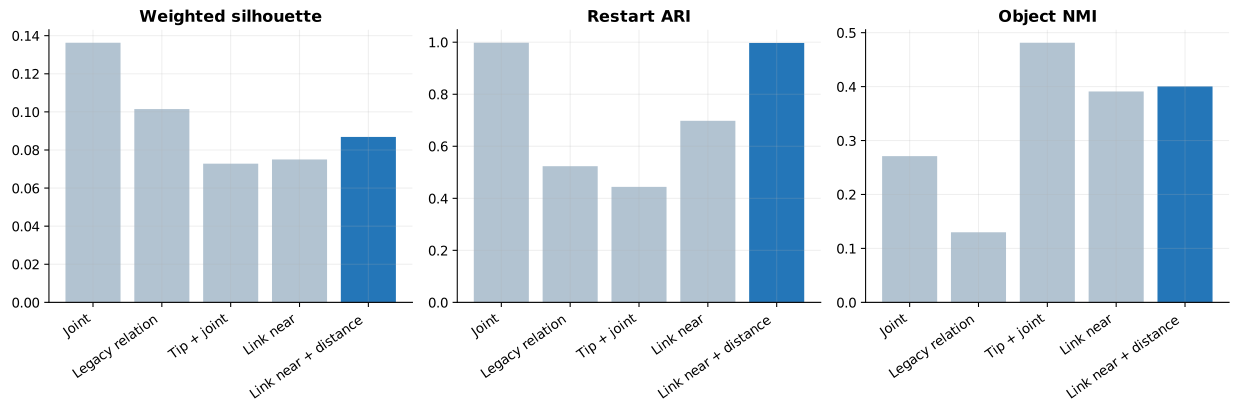
Compare all five representationsSame samples and K=6. Silhouette measures separation; ARI measures restart consistency. Object NMI measures association with object identity, not functional quality. / SVG / PNG
Representation
Silhouette ↑
Restart ARI ↑
Object NMI
PC1–2 variance
joint_only
0.136
0.998
0.271
38.3%
legacy_full_relation
0.101
0.523
0.130
28.8%
tip_relation_joint
0.073
0.444
0.481
24.9%
link_near_joint
0.075
0.698
0.391
25.9%
link_near_and_distance_joint
0.087
0.997
0.400
27.8%
02
Six clusters, observed representatives
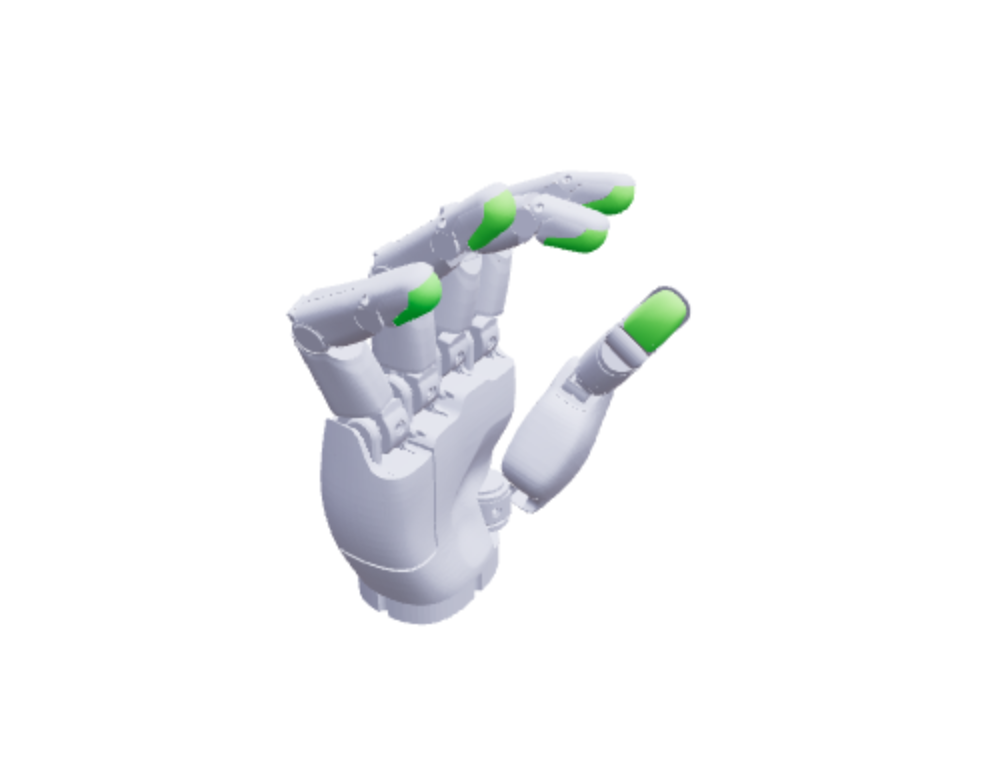
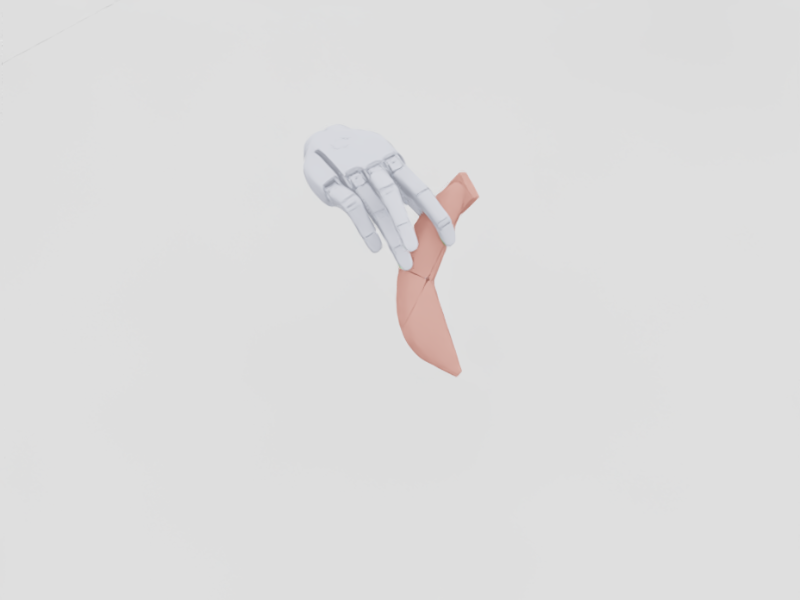
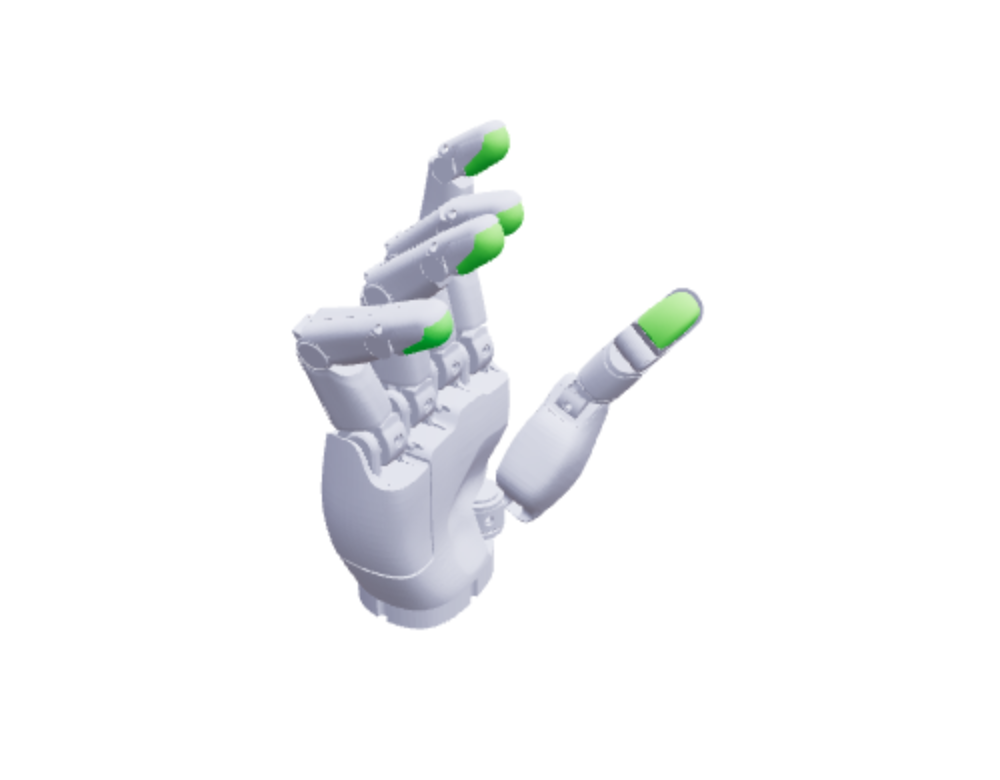
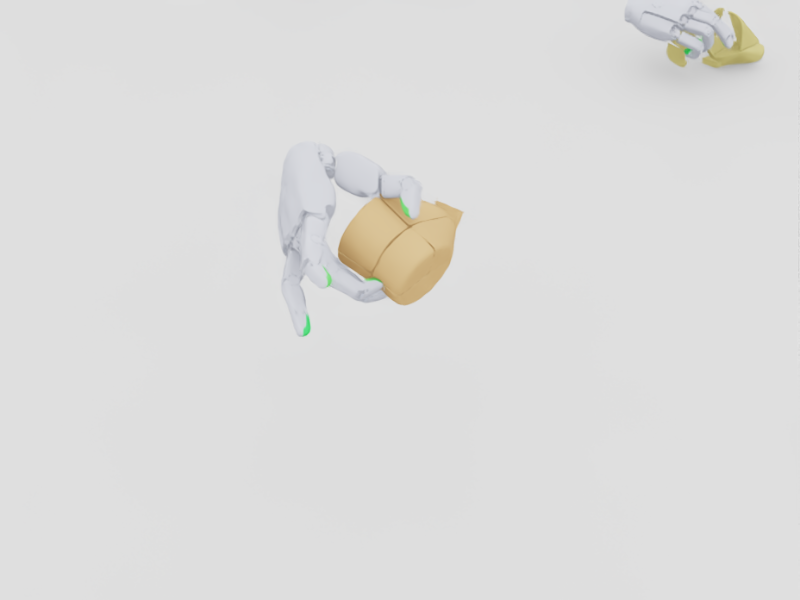
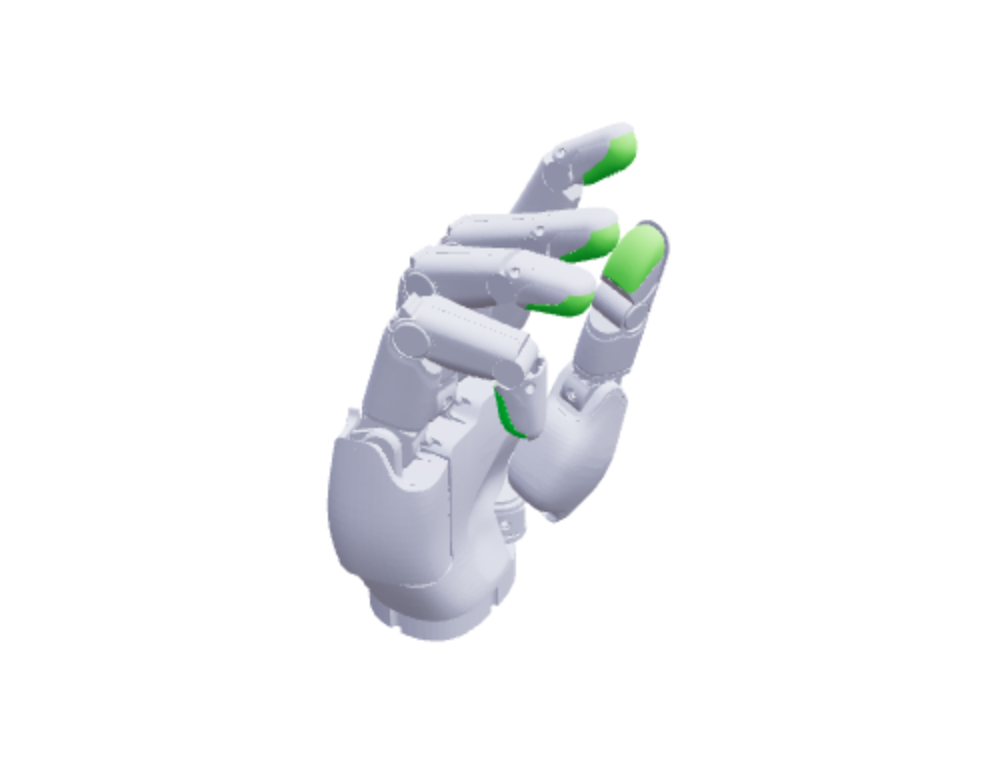
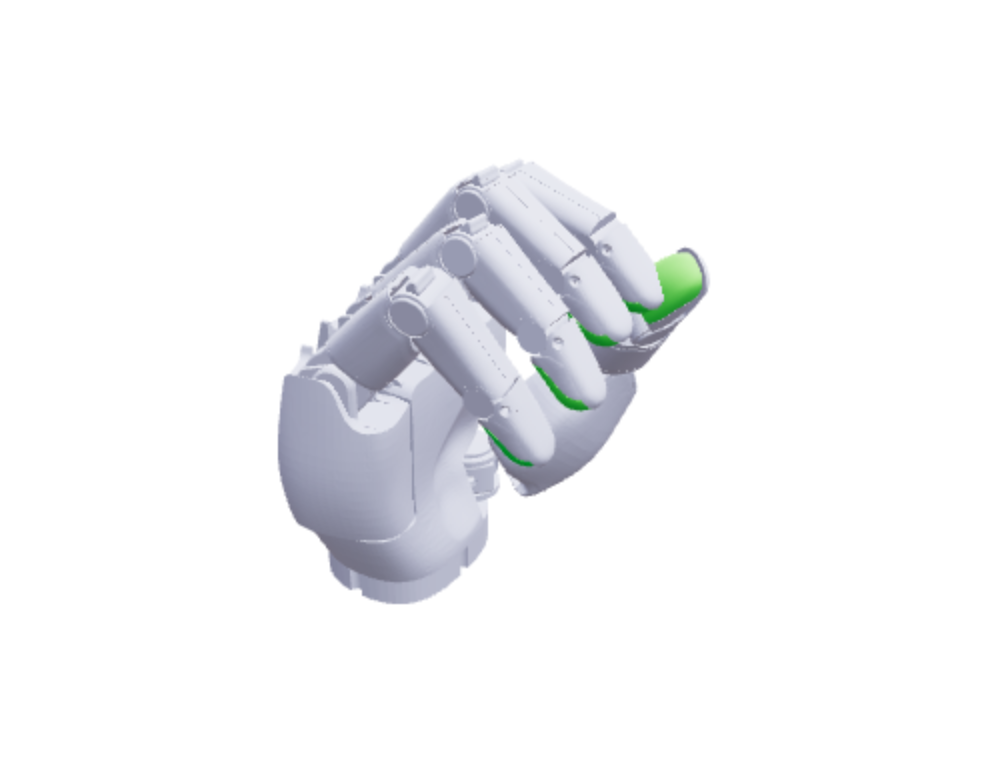
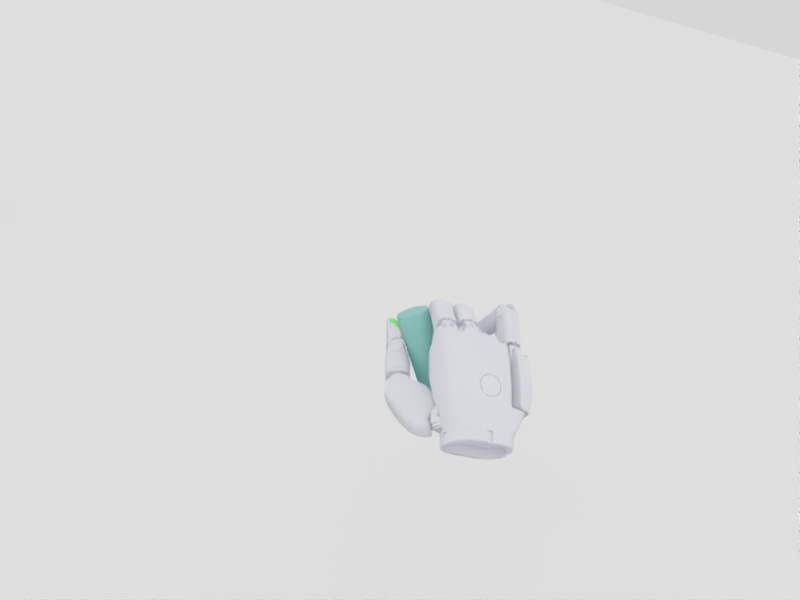
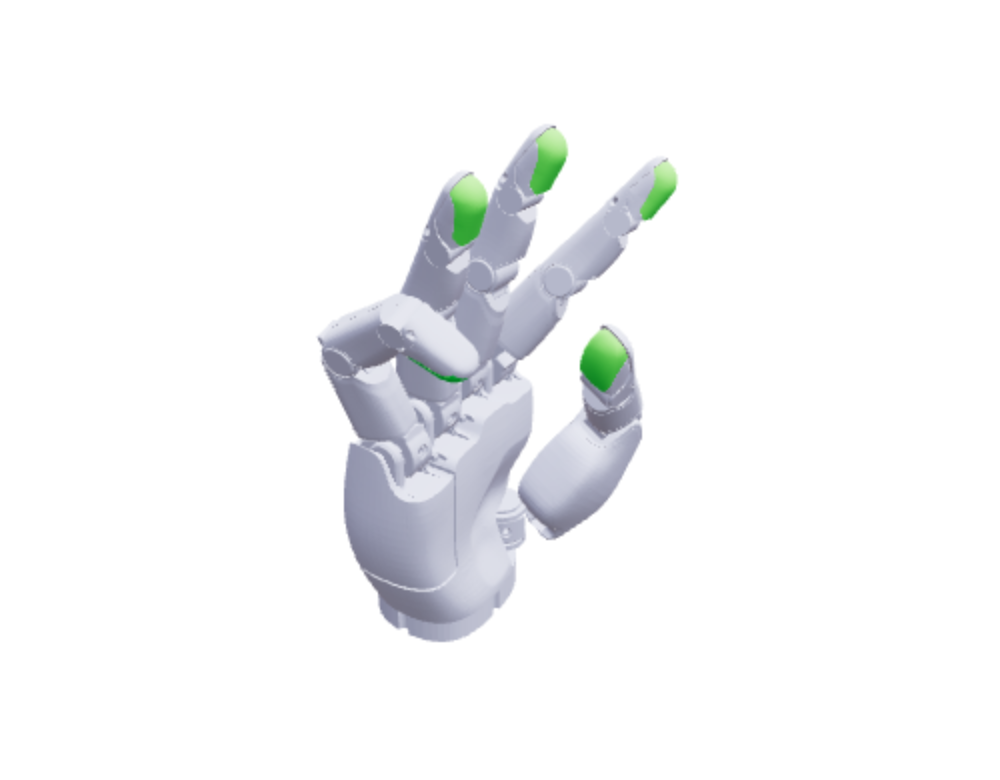
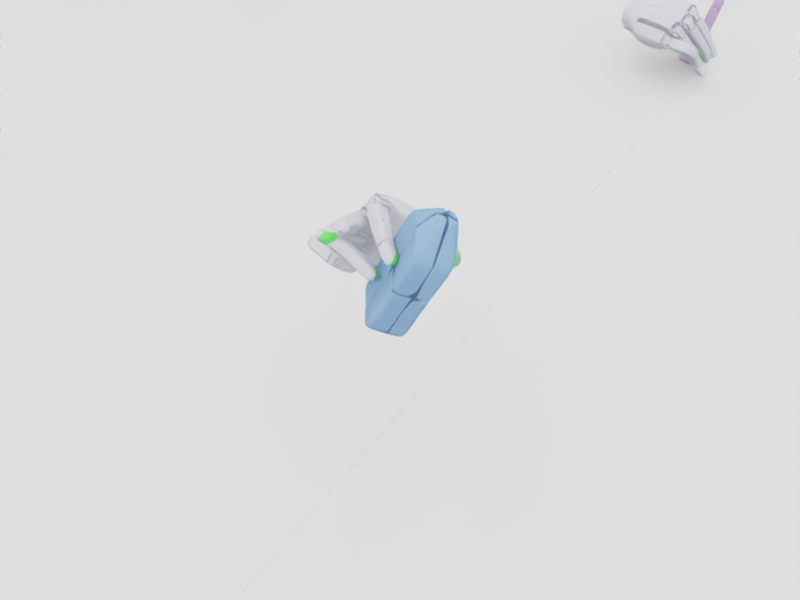
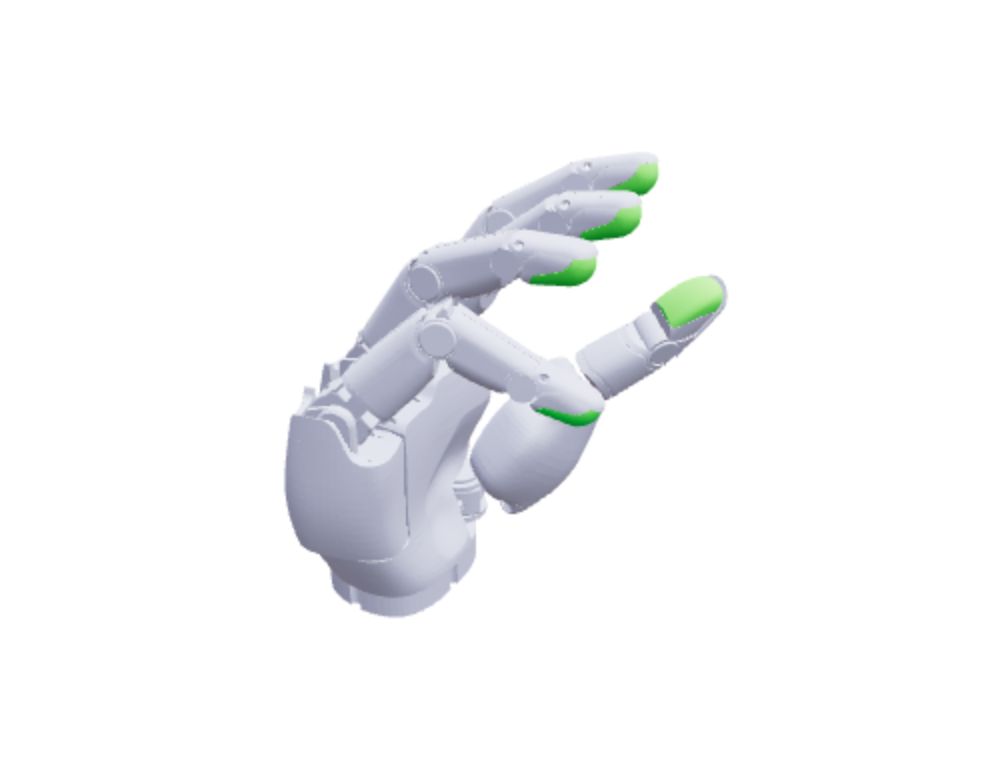
Each representative is an observed sample nearest its cluster center. Compare its hand pose with a recorded teacher interaction from the same final cluster; these are different frames and references. The C4 representative has no link within 5 mm of the object, so these groups should not all be interpreted as stable grasp types.
C0
2,278 samples
Observed representative / frame 7Teacher lift frame / different from the medoid
Scenes are mapped to final clusters by exact trajectory key. These are saved HOLD frames, not the configurations used for clustering; not every scene has passed strict success filtering.
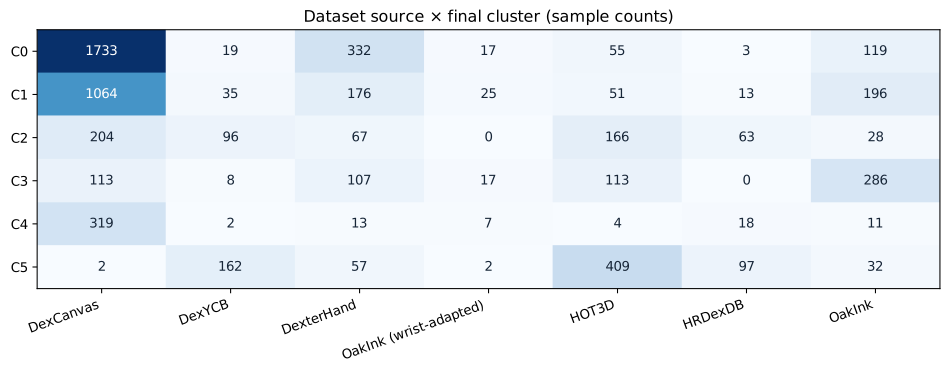
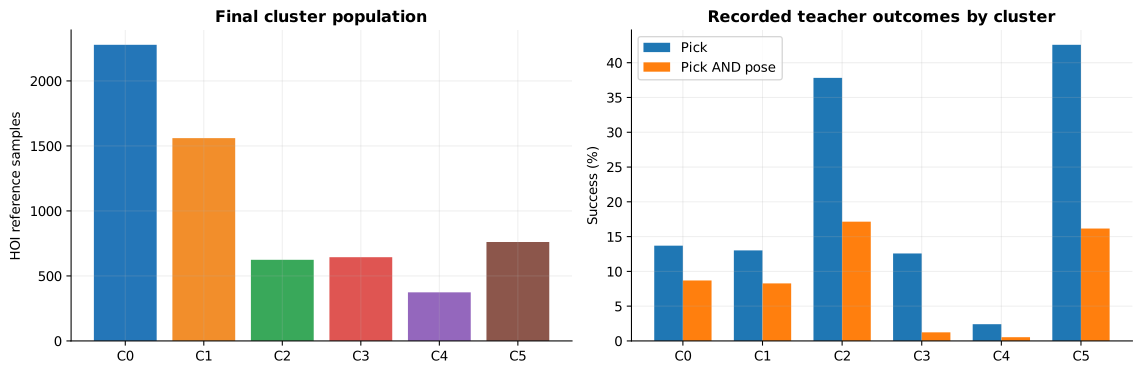
Dataset sources and final clusters. HOT3D, DexYCB, OakInk and HRDexDB entries processed through SPIDER are attributed to their original sources by reference key. / SVG / PNGOutcomes come from historical teacher evaluations. Correlation between representation and success does not establish that clustering improved policy performance. / SVG / PNG
Cluster
Samples
Lift success
Lift + pose tracking
Recorded examples
C0
2278
312 / 2278 (13.7%)
198 / 2278 (8.7%)
1
C1
1560
203 / 1560 (13.0%)
129 / 1560 (8.3%)
1
C2
624
236 / 624 (37.8%)
107 / 624 (17.1%)
1
C3
644
81 / 644 (12.6%)
8 / 644 (1.2%)
1
C4
374
9 / 374 (2.4%)
2 / 374 (0.5%)
1
C5
761
324 / 761 (42.6%)
123 / 761 (16.2%)
1
03
Recorded teacher interactions
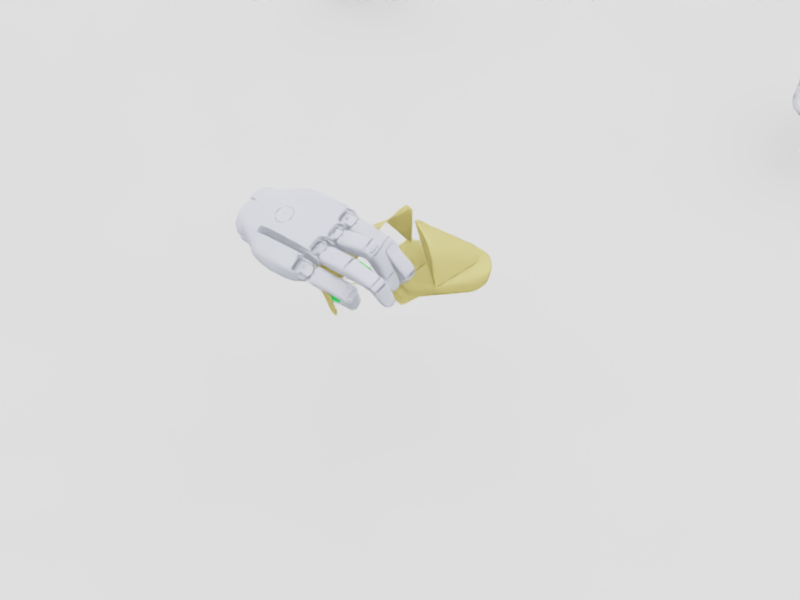
One example per final cluster, using General teacher model_5200.pt. The wrist follows its reference while the teacher controls the fingers. These color recordings are matched by complete reference identity and trimmed to the original display durations. Their original rollout measurements remain linked separately.
Stable tail HOLD: in at least 95% of the final 30 simulation ticks, the object is lifted ≥2 cm and at least two target-contacting fingertips reach 0.5 N. These are selected examples, not an aggregate success rate or a five-second HOLD evaluation.
04
PCA: variance and reconstruction
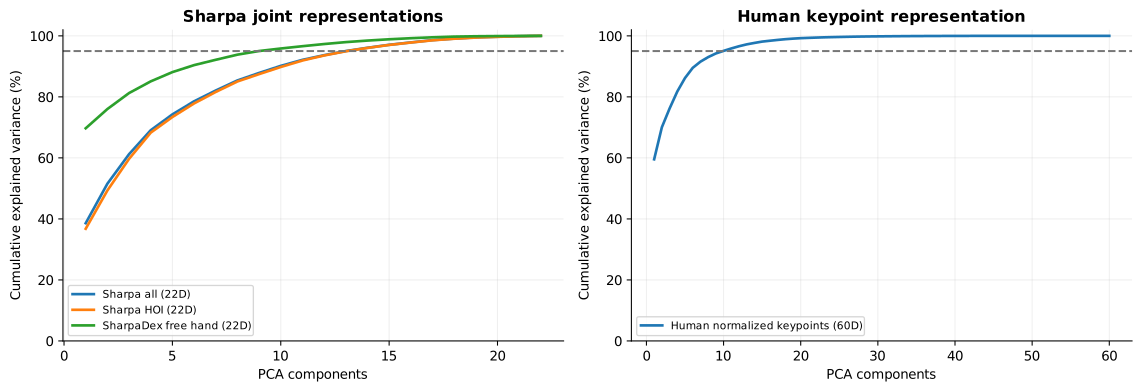
E1 indexes 1,029,112 poses, of which 1,015,044 satisfy URDF limits. A trajectory-key split and source-balanced sampling produce 8,867 fitting poses and 5,016 test poses. Sharpa uses 22 joint angles; the human analysis uses 60D hand-local landmarks normalized by hand length. These feature spaces are analyzed separately.
The component count for 95% variance depends on representation, population and weighting. It is not a ranking of intrinsic dexterity across hands. / SVG / PNG
Population / feature space
Input dimensions
Components for 95%
PC1–3 variance
Sharpa all (22D)
22
13
61.2%
Sharpa HOI (22D)
22
14
59.7%
SharpaDex free hand (22D)
22
9
81.2%
Human normalized keypoints (60D)
60
10
76.2%
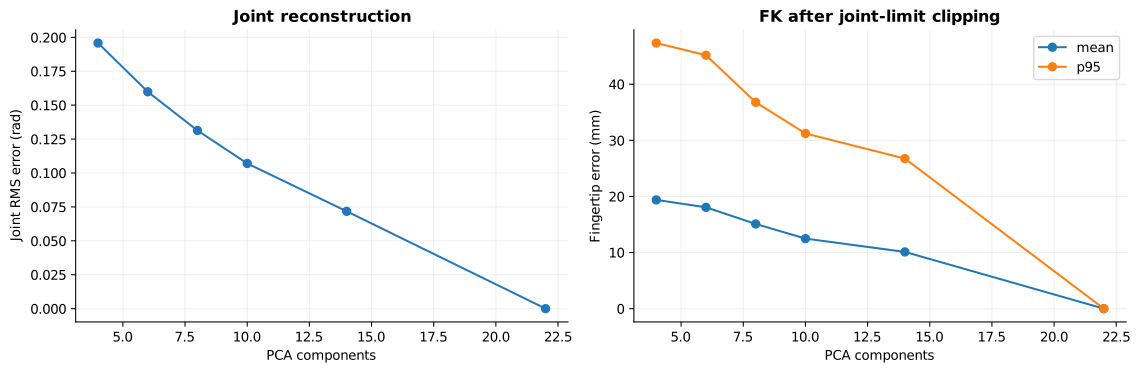
PCA-14 retains 96.1% of variance, yet fingertip FK reconstruction error after clipping still averages 10.1 mm, with a P95 of 26.7 mm. High variance retention does not guarantee precise contact geometry.
Joint RMS measures raw reconstruction error. Fingertip FK is evaluated after joint-limit clipping; limit violations are counted before clipping. / SVG / PNG
PCA dimensions
Variance retained
Joint RMS / rad
Outside limits before clipping
FK mean / mm
FK P95 / mm
4
69.1%
0.1958
44.0%
19.38
47.34
6
78.5%
0.1599
57.6%
18.06
45.17
8
85.4%
0.1313
60.0%
15.09
36.78
10
90.2%
0.1070
70.0%
12.48
31.22
14
96.1%
0.0717
76.0%
10.11
26.74
22
100.0%
0.0000
0.0%
0.00
0.00
05
Pose banks: coverage and transfer
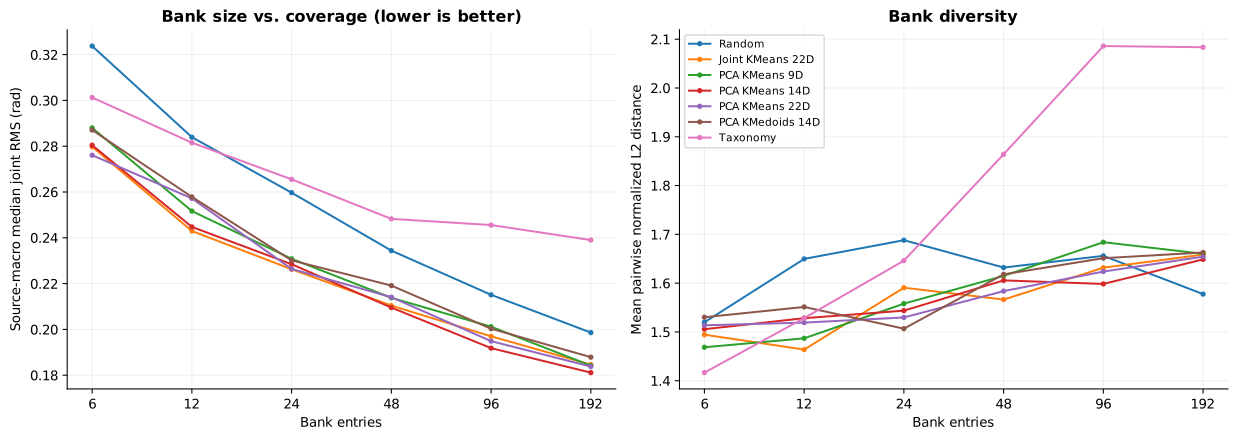
All exported bank entries are observed poses within joint limits. KMeans centers are replaced by their nearest training samples; approximate K-Medoids alternates over a candidate pool. Coverage is the mean of source-wise median nearest-pose errors, in radians. Diversity uses pairwise L2 distances after joint-range normalization.
Bank sizes K=6, 12, 24, 48, 96 and 192. Larger banks improve coverage, but increased diversity alone does not guarantee better nearest-neighbor coverage. / SVG / PNG
Method
6
12
24
48
96
192
Random
0.3237
0.2839
0.2597
0.2344
0.2151
0.1986
Joint KMeans 22D
0.2798
0.2430
0.2263
0.2104
0.1970
0.1846
PCA KMeans 9D
0.2880
0.2517
0.2308
0.2138
0.2012
0.1842
PCA KMeans 14D
0.2804
0.2447
0.2285
0.2095
0.1918
0.1811
PCA KMeans 22D
0.2761
0.2572
0.2264
0.2141
0.1949
0.1838
PCA KMedoids 14D
0.2871
0.2579
0.2301
0.2191
0.2003
0.1879
Taxonomy
0.3013
0.2815
0.2655
0.2483
0.2456
0.2390
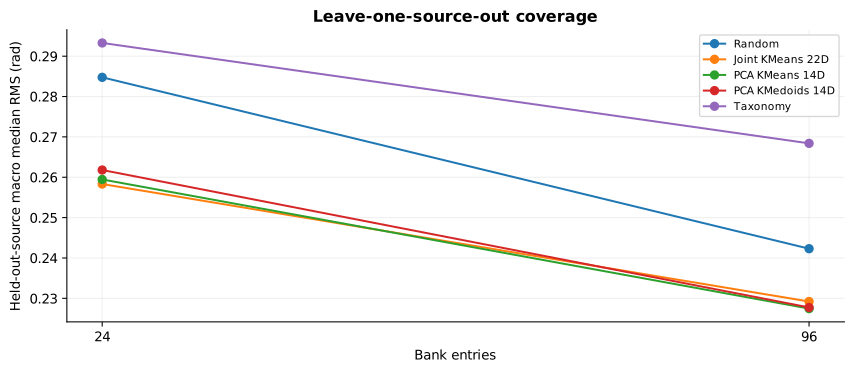
Leave one entire source out at a time, with equal weighting across 13 sources. Results shown for K=24 and K=96. / SVG / PNG
Method
K=24
K=96
Random
0.2848
0.2423
Joint KMeans 22D
0.2583
0.2292
PCA KMeans 14D
0.2594
0.2275
PCA KMedoids 14D
0.2618
0.2277
Taxonomy
0.2933
0.2684
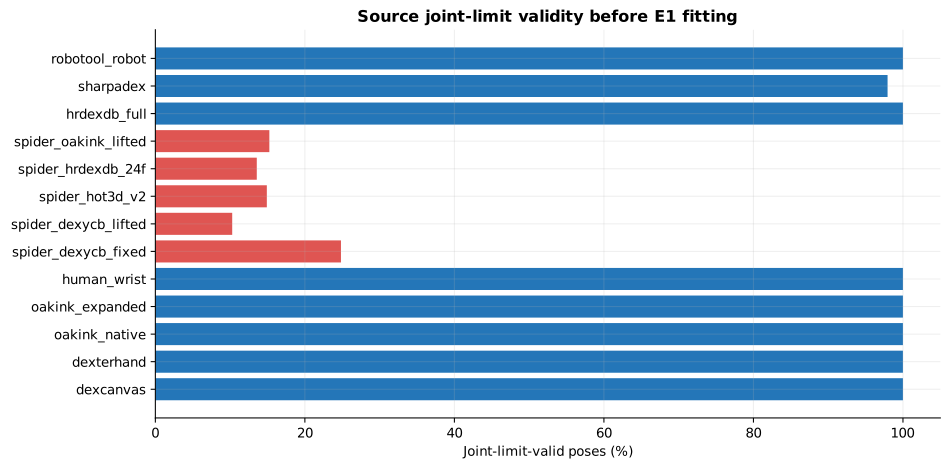
Kinematic validity and population limitsFraction of sampled poses within joint limits. E1 excludes invalid poses; offline limits and FK do not validate PhysX self-collision or grasp success. / SVG / PNG
Only about 10–25% of sampled poses in some SPIDER source subsets pass the current URDF limit check; the cause remains unresolved. Exported bank entries have zero joint-limit violations, but their PhysX self-collision pass rate has not been established.